
The agent action loop and how it stops
The loop is the mechanism; the stopping condition is the control that bounds it.
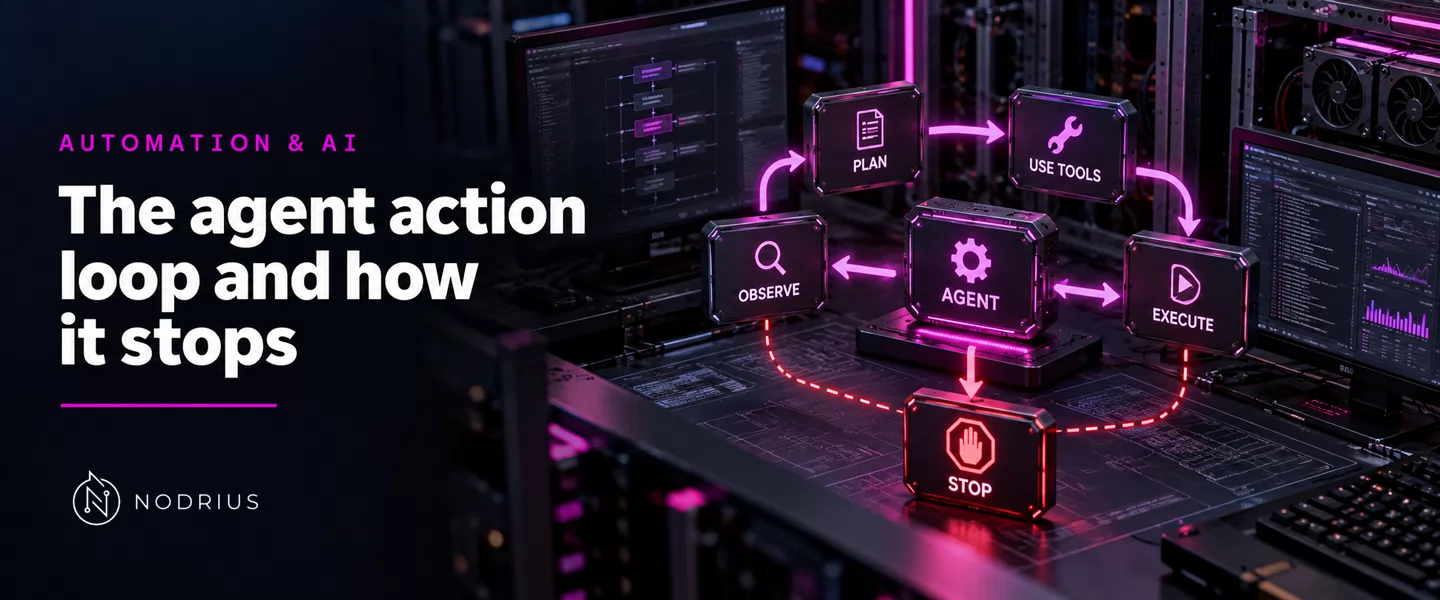
An agent is not a single model call; it is a model calling tools and reading their results until something tells it to stop. Anthropic draws the line this way: agents “are systems where LLMs dynamically direct their own processes and tool usage”, and in practice an agent is “typically just LLMs using tools based on environmental feedback in a loop.”
Because the loop is model-driven, nothing inside it decides when to quit. The stopping condition is a separate decision, and Anthropic says so plainly: the task “often terminates upon completion, but it’s also common to include stopping conditions (such as a maximum number of iterations) to maintain control.” This sheet is about that loop and the conditions — model-chosen and operator-imposed — that end it.
One turn: thought, action, observation
The pattern was named by the ReAct paper: “At time step t, an agent receives an observation ot” from the environment and “takes an action at” following a policy. Its contribution was to put reasoning inside that step; ReAct “prompts LLMs to generate both verbal reasoning traces and actions pertaining to a task in an interleaved manner.”
A thought is not an action. The paper is precise: a thought “does not affect the external environment, thus leading to no observation feedback” — it only updates the model’s own context. So a turn is a small sequence: the model writes a thought, emits an action (a tool call), the environment returns an observation, and the next decision is read off the trajectory so far. Anthropic stresses why the observation earns its place: it is “crucial for the agents to gain ‘ground truth’ from the environment at each step (such as tool call results or code execution) to assess its progress.” The loop is what makes a static model react to the real state of the world rather than its own first guess.
Two ways a loop ends
The first is completion. ReAct’s action space includes “(3) finish[answer], which would finish the current task with answer” — an action whose only effect is to end the trajectory. A modern runtime reaches the same end when the model answers instead of calling a tool: OpenAI’s Agents SDK “loops over the LLM until either” “A final-output tool is invoked” or “The model returns a response without any tool calls”, and the guide calls this “a while loop” that is “central to the functioning of an agent.”
The second is a bound. Anthropic’s “maximum number of iterations” is a stop imposed from outside the model. It is the only exit that does not depend on the model being right — which is exactly why it holds when completion never arrives.
When completion never arrives
The failure the bound guards against is documented in ReAct: “there is one frequent error pattern
specific to ReAct, in which the model repetitively generates the previous thoughts and actions, and we
categorize it as part of ‘reasoning error’ as the model fails to reason about what the proper next
action to take and jump out of the loop.” A model repeating its own last steps will not converge on
finish[answer]. Without an external bound it continues until something else ends it — a timeout, a
cost ceiling or a permission check. A bound is not a formality wrapped around the loop: it is the
control for the bad path, and it should be chosen deliberately rather than discovered in production.
Stopping is not always finishing
A stop can be a pause rather than an end. ReAct showed the pause already: human-in-the-loop interaction lets a person “inspect and edit ReAct’s reasoning traces”, changing the trajectory mid-loop. In graph-based runtimes the pause is a mechanism rather than a manual edit — an interrupt can “pause graph execution at specific points and wait for external input before continuing”, and the run is then expected to “resume after an interruption”. The consequence: a completion stop closes the work; a pause stop suspends it with its state intact, and resuming belongs to the state and checkpoint sheet of this layer. An agent that has merely paused has not finished.
What to keep
The loop is the agent’s mechanism, and its exit is a decision the builder makes, not a property the model has. Completion stops are the model’s answer; bound stops are the operator’s guarantee. A system needs both — a finish condition for the ordinary case and a bound for the case where the model never reaches it — and pausing for a human is a third stop. None of the three is automatic; each has to be named, chosen and tested.
Level and prerequisites. L4 — the advanced layer of the area, where the pieces named in the earlier sheets are assembled into a running control loop and the reader must reason about what keeps it bounded. Prerequisites: the L1 sheets on how a model generates text and what a context window is, the L2 sheet on tool calling and structured output, and the L3 sheet of this area that separates chatbots, workflows and agents, which fixes the vocabulary this sheet leans on.
Where to go next
- Automation & AI — the macro-area this sheet belongs to.
- Applications — the node this sheet sits in.
References
- Anthropic — Building effective agents — the definition of agents versus workflows, the environmental-feedback loop, and the maximum-iterations stopping condition.
- Yao et al. — ReAct: Synergizing Reasoning and Acting in Language Models — the
thought-action-observation step, the non-environmental thought, the
finish[answer]action and the repetitive-loop failure mode. - OpenAI — A practical guide to building agents — the run loop and its two exit conditions.
- LangChain — LangGraph persistence — the pause-and-resume stop, distinguished from completion.